
New
AuthorizedRobot Platforms
MagicBot X1
MagicLab
Full-size humanoid — 180 cm, 31 DOF, ≥400 N·m joints, hot-swappable dual battery
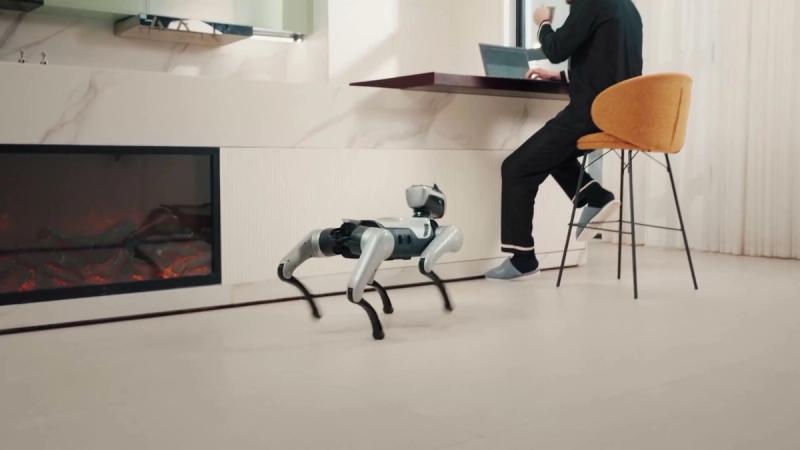
Quadruped robot for secondary development and robotics teaching
MagicDog in the education configuration, supplied for secondary development. Adds open SDK access, sensor interfaces and sample projects on top of the standard quadruped platform, for university courses, laboratory work and student robotics projects.
| Configuration | Education / secondary development |
| Overall dimensions | 670 × 350 × 560 mm |
| Weight | 15.8 kg (without battery) |
| Maximum load | 10 kg |
| Effective payload | 5 kg |
| Maximum joint torque | Approx. 37.5 N·m |
| Maximum operating speed | 3 m/s |
| Maximum climbing height | 15 cm |
| Sensors | LiDAR, depth camera, 4K camera, ultrasonic sensor, touch sensor, microphone array |
| Development support | Graphical programming, SDK, open sensor interfaces, sample projects |
MagicLab
Full-size humanoid — 180 cm, 31 DOF, ≥400 N·m joints, hot-swappable dual battery
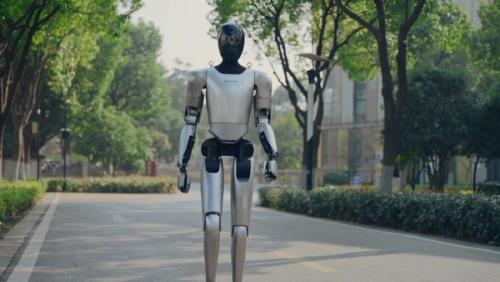
MagicLab
Full-size humanoid robot — 1740 mm, 42 DOF, 100 TOPS perception computing
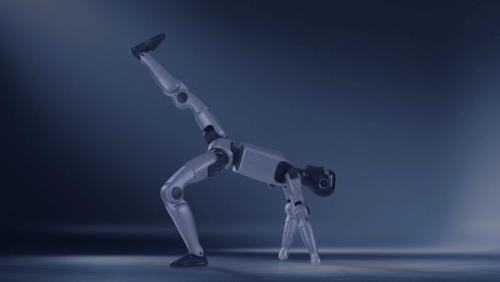
MagicLab
Half-size developer humanoid — 1369 mm, 24–50 DOF, quick-release battery
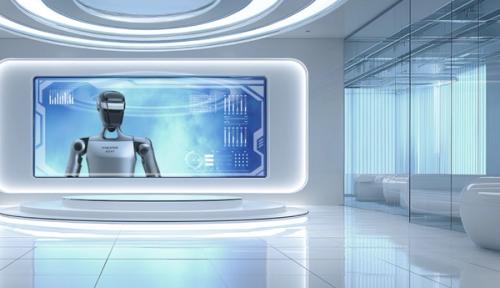
MagicLab
Z1 humanoid configured for automated guided tours and narration
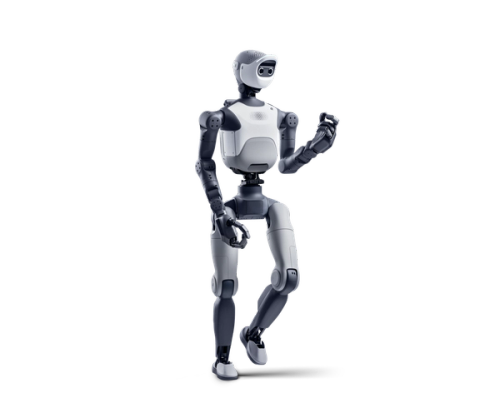
Agile Robots
Compact open humanoid platform for research
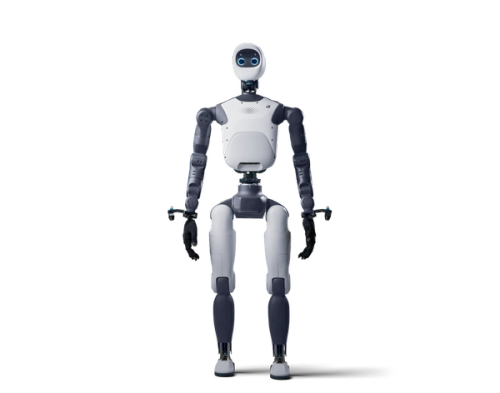
Agile Robots
Humanoid reference platform with NVIDIA Isaac GR00T
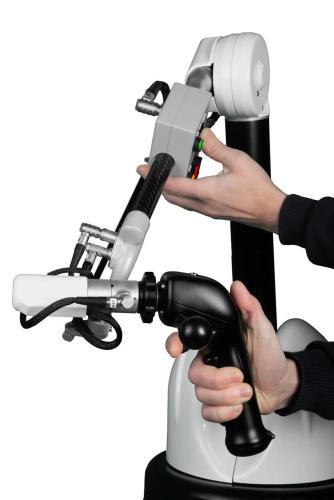

Franka Robotics
Six-axis haptic teleoperation device with force feedback for FR3 control.