
New
AuthorizedRobot Platforms
MagicBot X1
MagicLab
Full-size humanoid — 180 cm, 31 DOF, ≥400 N·m joints, hot-swappable dual battery
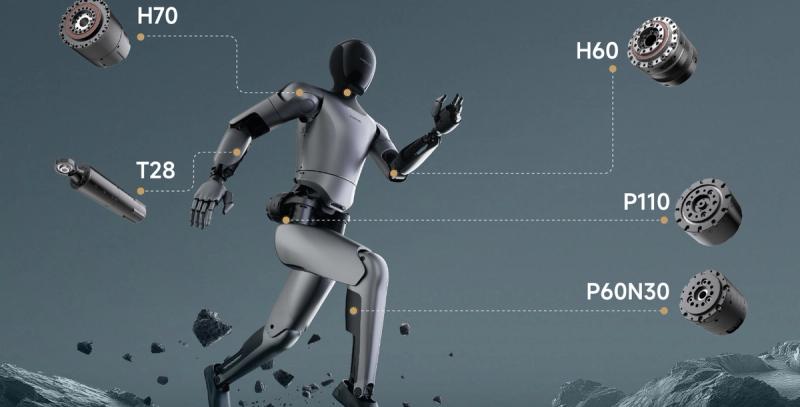
Planetary, harmonic and linear joint actuators from MagicLab's own humanoids — 25 to 360 N·m peak
The joint actuators MagicLab develops for its own humanoid and quadruped robots, offered as separate components. The range covers four planetary modules for legs, waists and arms (P110, P90N20, D90, P60N30), two harmonic modules for high-precision joints and collaborative arms (H70, H60), and the T28 ball-screw linear actuator for forearms and ankles. Rotary peak torque runs from 25 N·m on the compact D90 to 360 N·m on the P110, every module carries dual encoders, and most speak both CAN and EtherCAT. Several models support internal cable routing through the joint. Pick the module per joint, or ask us for a matched set for a new robot design.
| P110 — planetary | Ø112 × 71.5 mm · 1900 g · 360 N·m max / 90 N·m rated · 120 rpm · 48–54 V · dual encoders 15-bit · CAN/EtherCAT · internal routing optional |
| P90N20 — planetary | Ø92 × 63.4 mm · 1100 g · 130 N·m max / 35 N·m rated · 300 rpm · 48–54 V · dual encoders 18-bit · CAN/EtherCAT · internal routing yes |
| D90 — planetary | Ø98 × 48.5 mm · 590 g · 25 N·m max / 9 N·m rated · 180 rpm · 24–36 V · dual encoders 12-bit · CAN · internal routing no |
| P60N30 — planetary | Ø64 × 57.1 mm · 532 g · 60 N·m max / 20 N·m rated · 175 rpm · 48–54 V · dual encoders 15-bit · CAN/EtherCAT · internal routing no |
| H70 — harmonic | Ø70 × 96 mm · 900 g · 90 N·m max / 30 N·m rated · 30 rpm · 48–54 V · dual encoders 19-bit · CAN/EtherCAT · internal routing yes |
| H60 — harmonic | Ø64 × 60 mm · 590 g · 90 N·m max / 33 N·m rated · 39 rpm · 48–54 V · dual encoders 19-bit · CAN/EtherCAT · internal routing yes |
| T28 — linear (ball screw) | Ø32 × 155 mm · 340 g · 750 N max / 300 N rated thrust · 116 mm/s · 40 mm stroke · 48 V · dual encoders 18-bit · RS485 |
| Intended use — planetary series | Legs, waist or arms of full-size and mid-size humanoids; leg joints of consumer and industrial quadrupeds |
| Intended use — harmonic series | High-precision joints in legs, waists, arms and collaborative robot arms |
| Intended use — linear module | Forearms, ankles and other joints that need precise linear force |
MagicLab
Full-size humanoid — 180 cm, 31 DOF, ≥400 N·m joints, hot-swappable dual battery
MagicLab
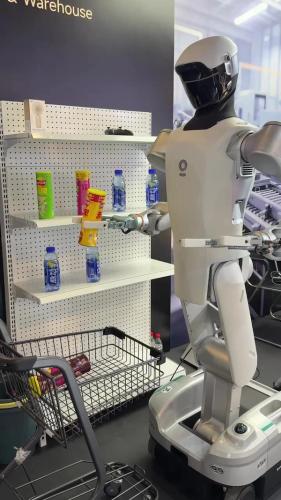
Wheeled humanoid — 7-DOF force-controlled arms, omnidirectional base, Jetson Thor
MagicLab
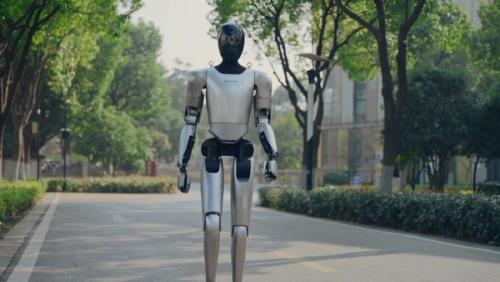
Full-size humanoid robot — 1740 mm, 42 DOF, 100 TOPS perception computing
MagicLab
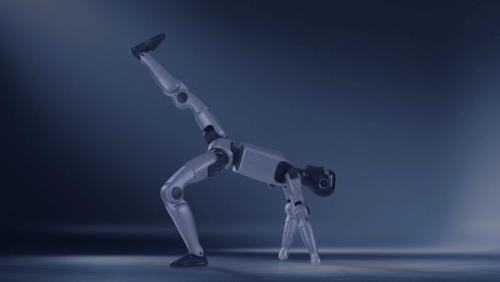
Half-size developer humanoid — 1369 mm, 24–50 DOF, quick-release battery