New
Own brandRobot Platforms
M1
MegaRobotics
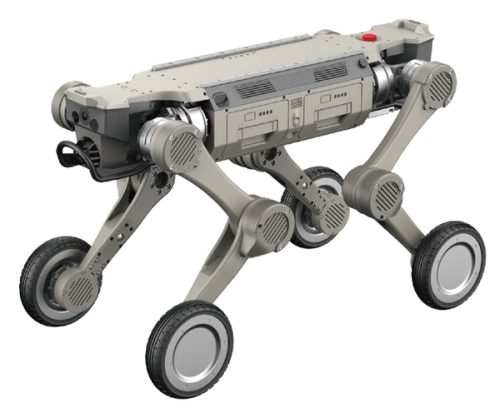
A wheel-legged quadruped that rolls fast on the flat and walks where wheels give up.
Contact for pricing
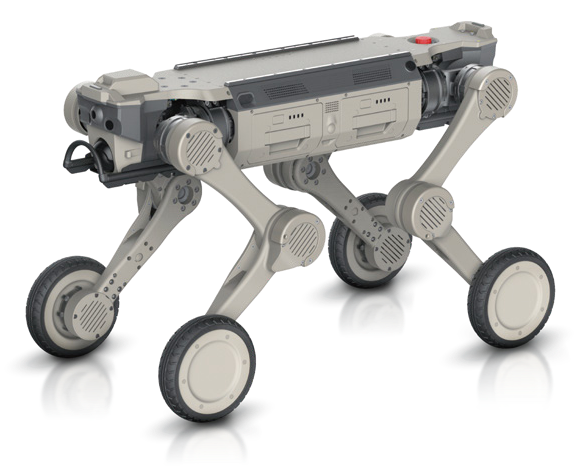
720° surround perception and 128 TOPS of onboard compute on the M1 platform.
The M1 Ultra is the top model of the series, built for sites where the robot has to see everything around it. Four 3 MP fisheye cameras and two 2 MP stereo cameras give 720° surround perception as standard, and a 6-core processor with 128 TOPS runs the perception and autonomy software on board. Everything from the M1 Pro is included: navigation and mapping, follow mode using UWB, LiDAR and vision, ultrasonic sensors and a voice intercom with broadcast. The platform is the same as the M1: twelve joint motors and four wheel hub motors, 41 kg, 30 kg payload while walking, 6 m/s, IP67, two 3D LiDARs, a depth camera and RTK, and up to 5 hours unloaded on two hot-swap batteries. MegaRobotics supplies, integrates and services the M1 Ultra in the DACH region, built by an OEM manufacturing partner. CE conformity is in preparation. The M1 Ultra has no explosion protection and is meant for areas outside classified Ex zones. Product images are renderings and may differ from the delivered unit.
| Dimensions standing (L × W × H) | 930 × 480 × 595 mm |
| Dimensions lying down (L × W × H) | 930 × 630 × 210 mm |
| Weight incl. batteries | 41 kg |
| Drive | 12 joint motors + 4 wheel hub motors |
| Peak joint torque | 180 N·m |
| Payload while walking | 30 kg |
| Speed | 6 m/s, peaks of 8 m/s |
| Stairs | Steps up to 25 cm, continuous |
| Max. obstacle height | 80 cm |
| Max. slope | 45° |
| Battery | 2 × 54 V / 9.35 Ah (1,010 Wh in total), hot-swap |
| Charging time | Under 2 h |
| Range and endurance | 29 km / 5 h unloaded, 18 km / 3.5 h at full load (measured at 1 m/s) |
| Ingress protection | IP67 |
| Operating temperature | −20 to +55 °C (−40 to +80 °C with optional wide-temperature battery) |
| Explosion protection | None |
| Main computer | 6-core CPU, 128 TOPS |
| Storage | 256 GB + 512 GB TF card |
| Cameras | 4 × 3 MP fisheye + 2 × 2 MP stereo |
| Further standard sensors | 2 × 3D LiDAR (front and rear), depth camera, IMU, RTK, ultrasonic, 4 fill lights |
| 720° surround perception | Standard |
| Navigation and mapping | Standard |
| Follow mode | UWB, LiDAR and vision |
| Voice | Intercom and broadcast |
| Obstacle avoidance | Supported |
| Motion modes | Crawl for narrow passages, stair climbing, high platforms, rodent barriers |
| Interfaces | 2 × Gigabit Ethernet, 2 × USB 3.0, RS232, RS485, 2 × SBUS, PPS |
| Payload power | 12 / 24 / 48 V, switchable via SDK |
| Wireless | Wi-Fi, Bluetooth |
| Software | Open SDK (C++, Ubuntu 22.04), ROS 2 Humble with Nav2, URDF models, simulator; scope confirmed per quotation |
| Scope of supply | Charger, charging dock, remote control, transport case |
| Options | Charging station for autonomous recharging, point-foot kit, wide-temperature battery |
| CE conformity | In preparation |
| Values as of | 11/2026; subject to change |
MegaRobotics
A wheel-legged quadruped that rolls fast on the flat and walks where wheels give up.
MegaRobotics
The M1 with navigation, mapping, follow mode and two-way voice built in.
MegaRobotics
The heavy-duty walking robot for 50 kg payloads, IP67 and long outdoor shifts.
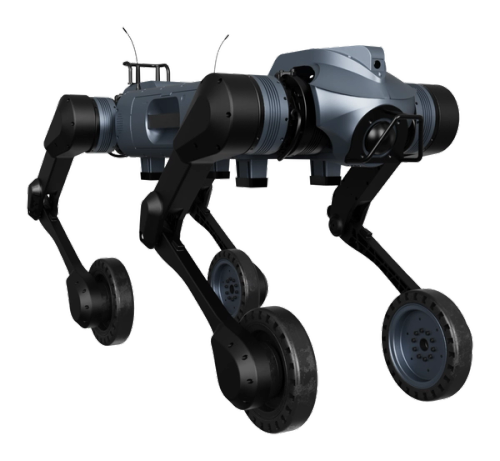
MegaRobotics
Heavy-duty wheel-legged platform: 50 kg payload, up to 6 hours, 40 cm obstacles.
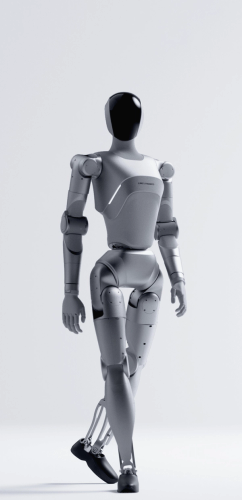

LimX Dynamics
Limitless Art, Fluid Motion
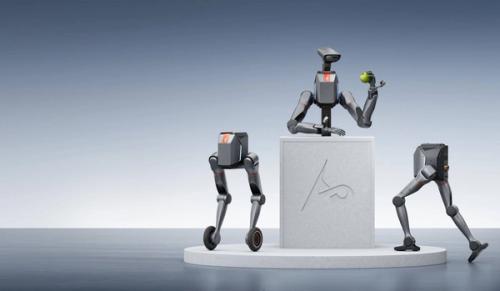
LimX Dynamics
Multi-Form Embodied Robot with Cutting-edge Algorithms
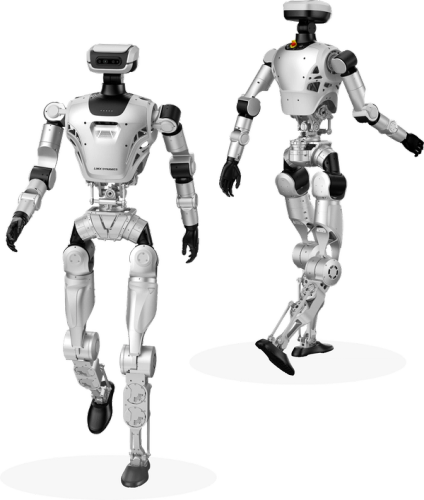
LimX Dynamics
Full-Size General-Purpose Humanoid Robot - Cross the Limits with Oli
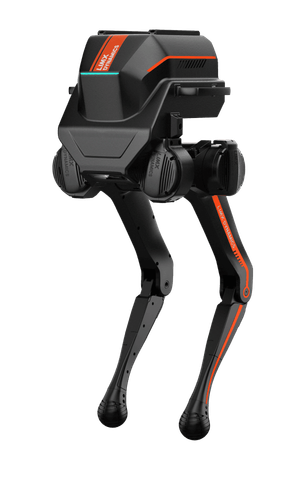
LimX Dynamics
The First Multi-Modal Biped Robot — The Gateway to Humanoid RL Research